Multi-modal hardware
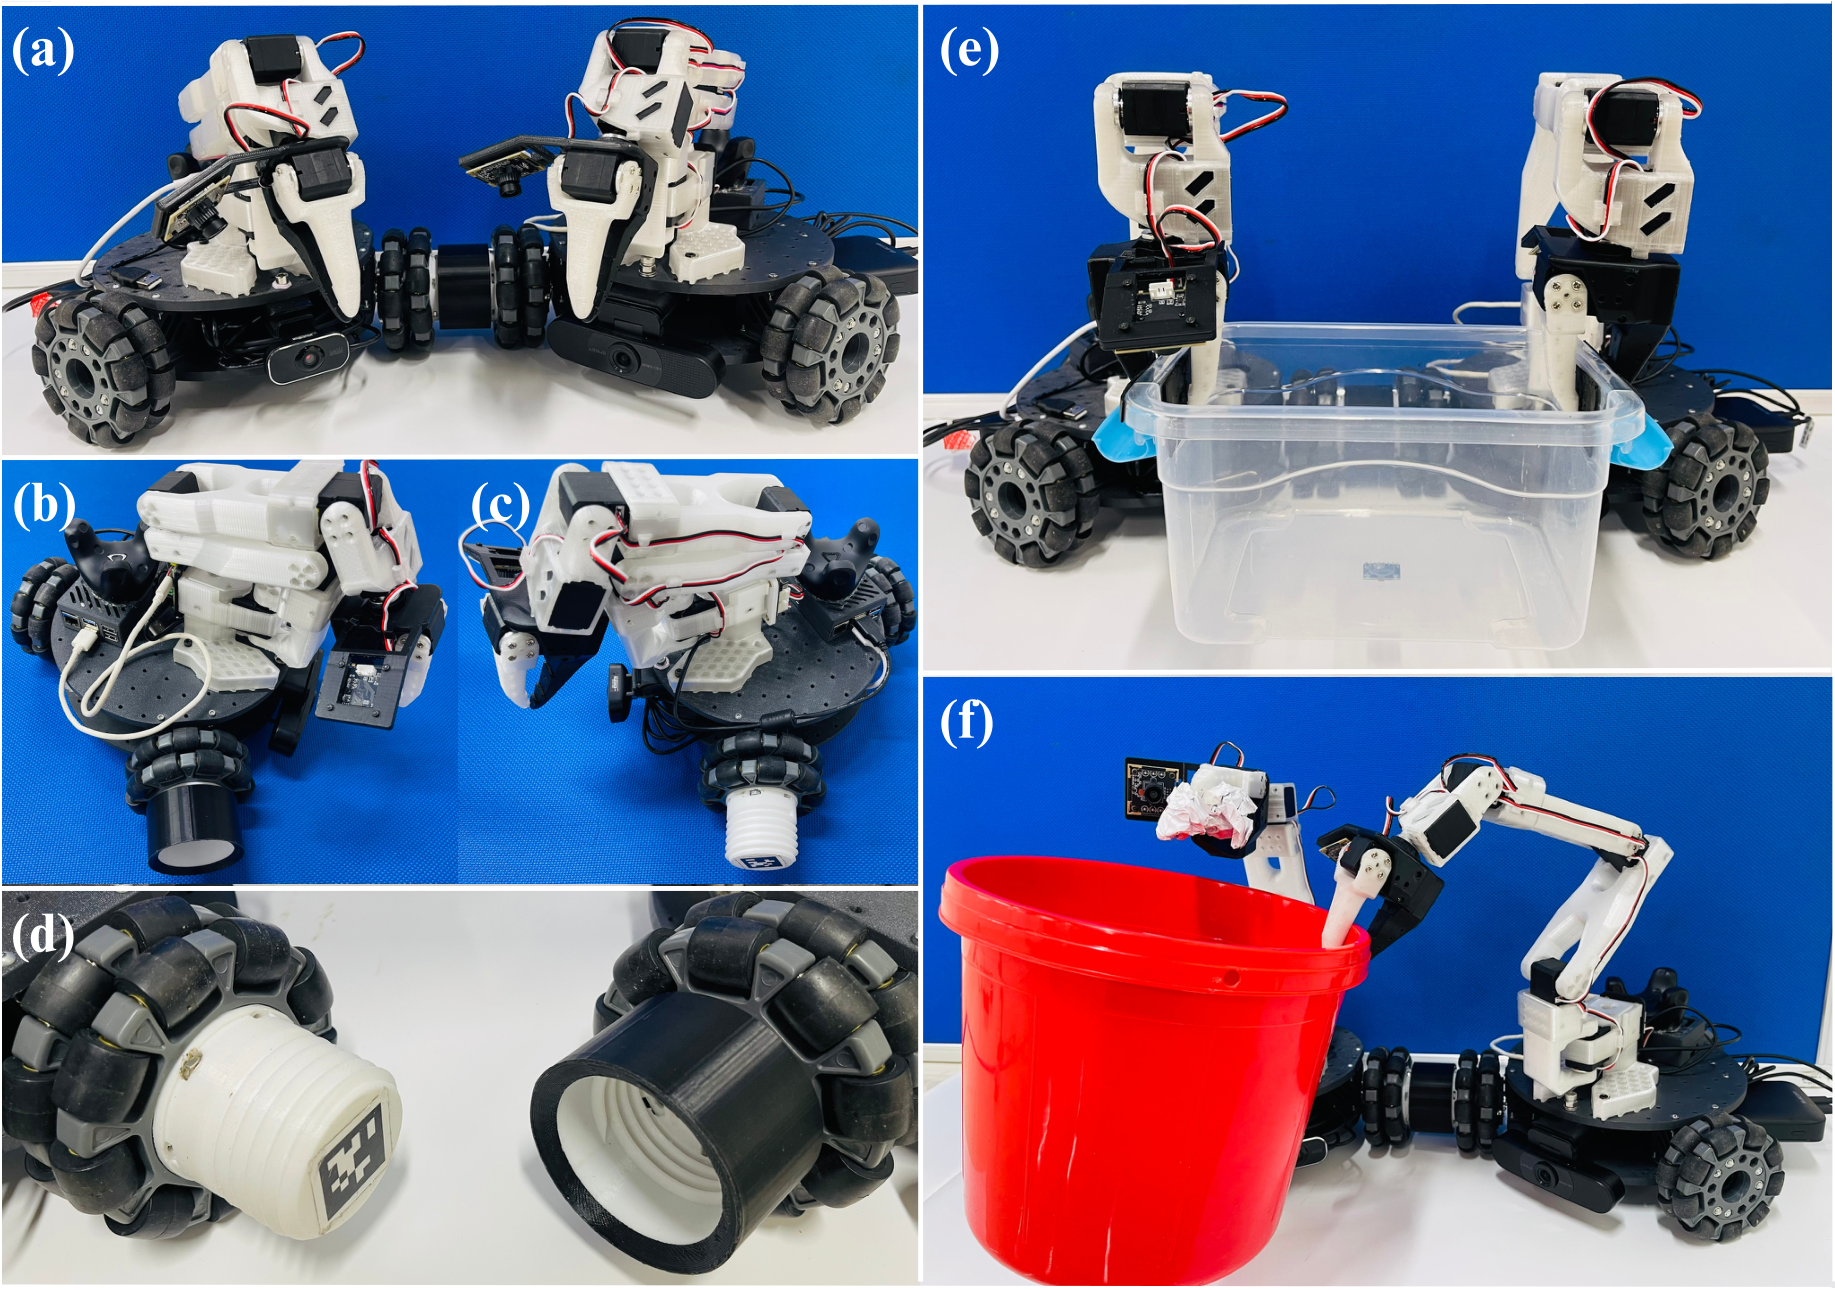
Switch between independent mobile manipulators and a rigid, unified bimanual configuration.
Design and Control of a Modular Self-Reconfigurable
Bimanual Mobile Manipulator via Robotic Docking
1Hanoi University of Science and Technology · 2The University of Tokyo
3University of Liverpool · 4Keio University
†Equal contribution
Watch the complete system demonstration, including autonomous alignment, physical docking, unified motion, and collaborative manipulation.
Multi-robot mobile manipulators are flexible, but coordinating them during collaborative tasks introduces communication, control, and dynamic-stability challenges. MobiDock adds a physical docking mode: two independent robots autonomously connect and become one rigid bimanual platform.
A vision-guided approach and threaded screw-lock mechanism establish a zero-backlash connection. After docking, a unified control law treats the assembly as a single kinematic entity—reducing coordination overhead while preserving the option to separate for independent tasks.
Switch between independent mobile manipulators and a rigid, unified bimanual configuration.
Vision-based alignment, mechanical locking, and post-docking control in one framework.
Benchmarking shows improved stability, angular precision, and task efficiency.
Each module combines a 6-DOF arm with a triangular three-wheel omnidirectional base. The base-mounted docking interface enables rigid physical reconfiguration without sacrificing mobility.
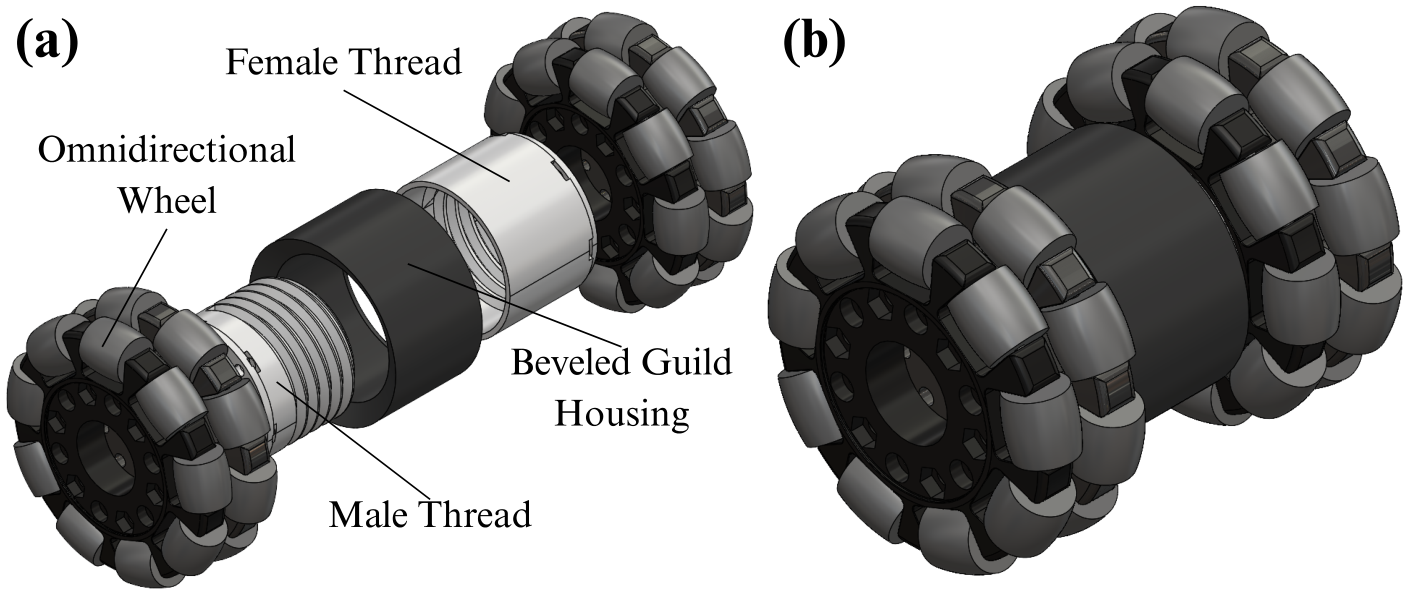
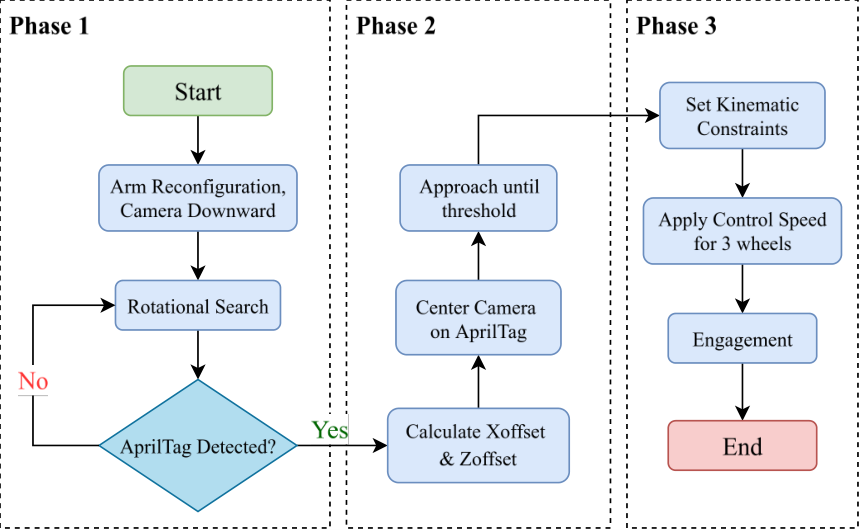
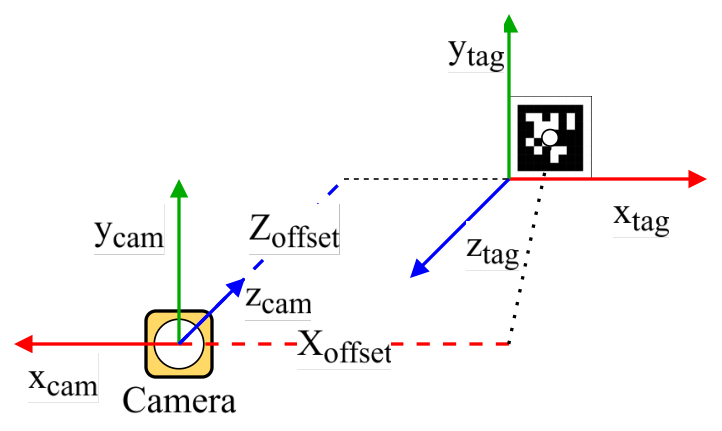
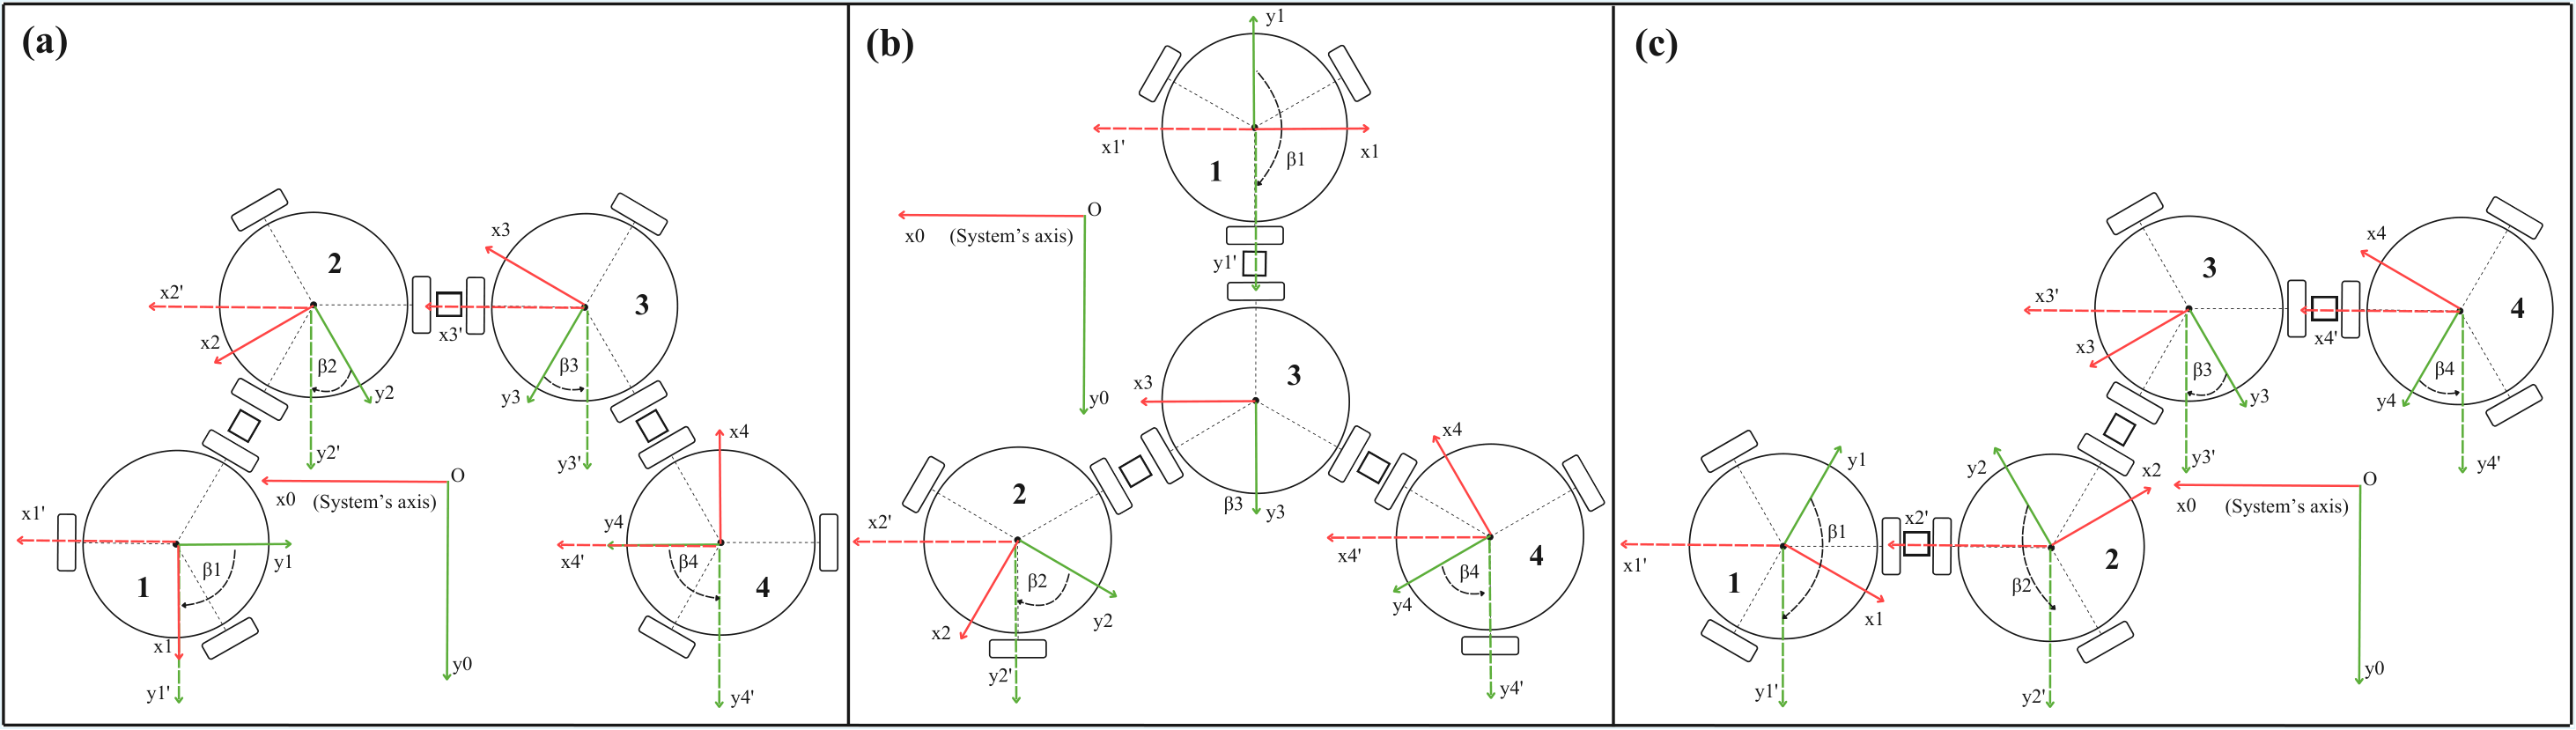
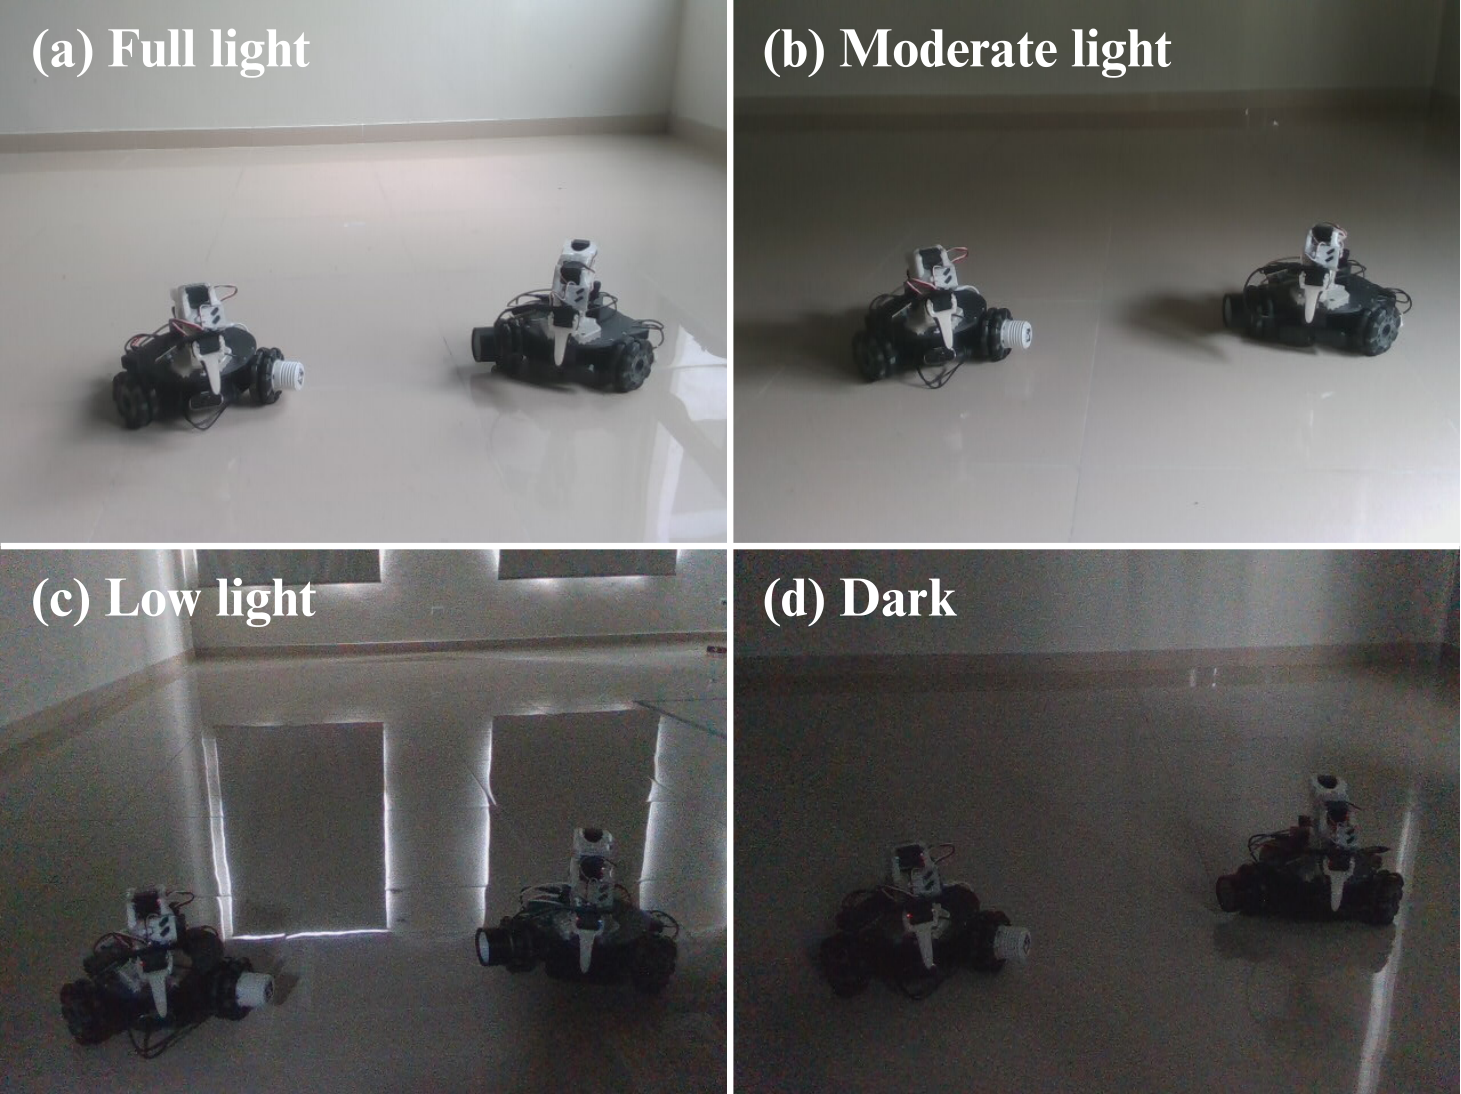
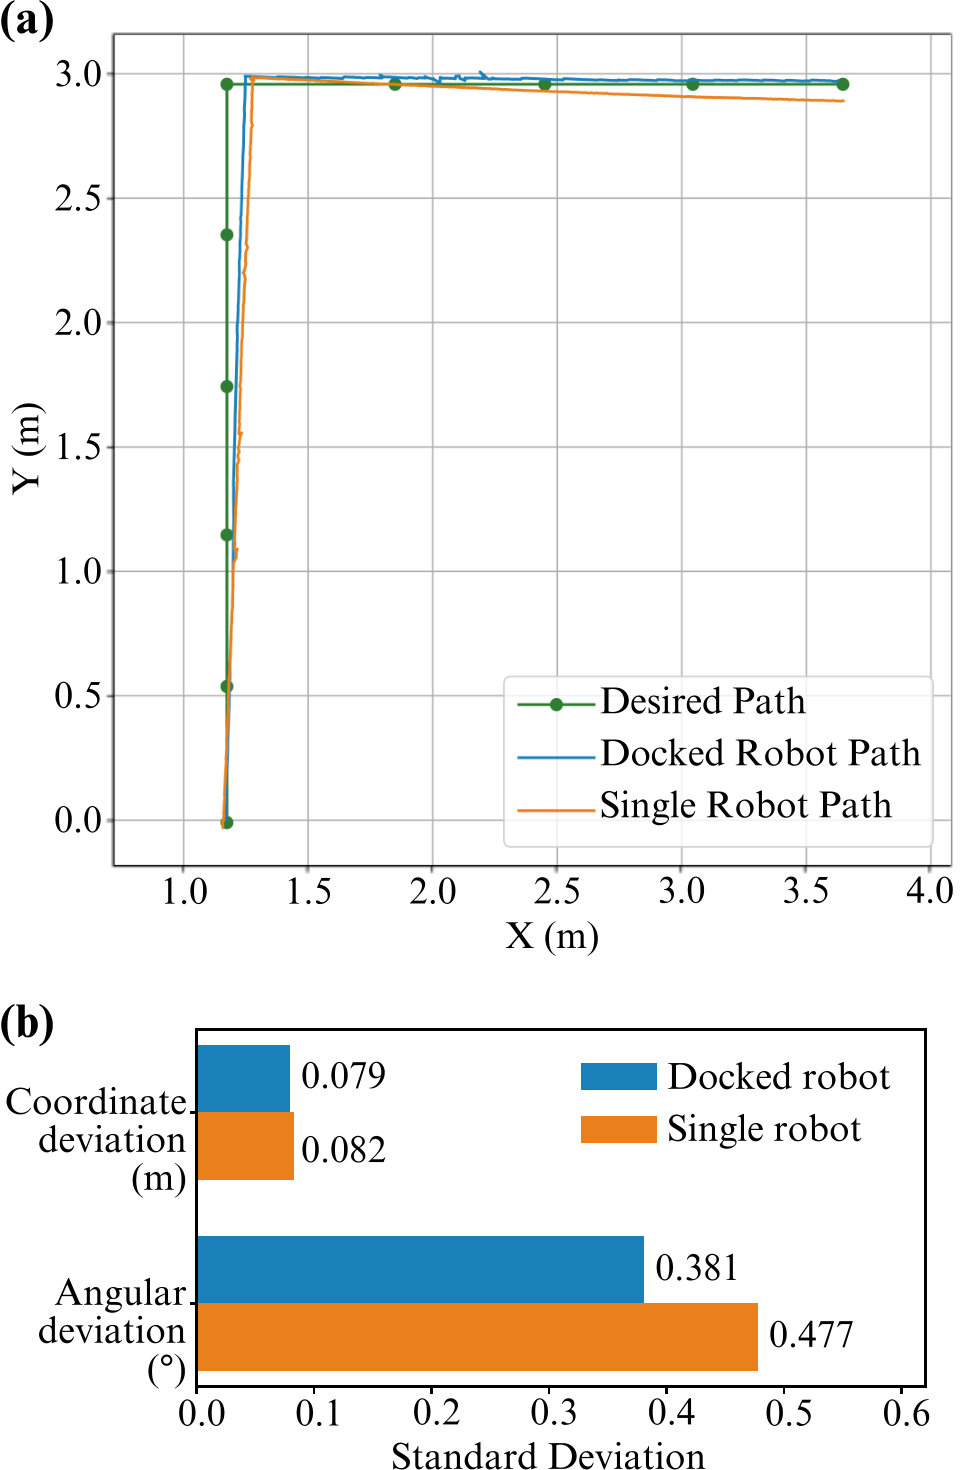
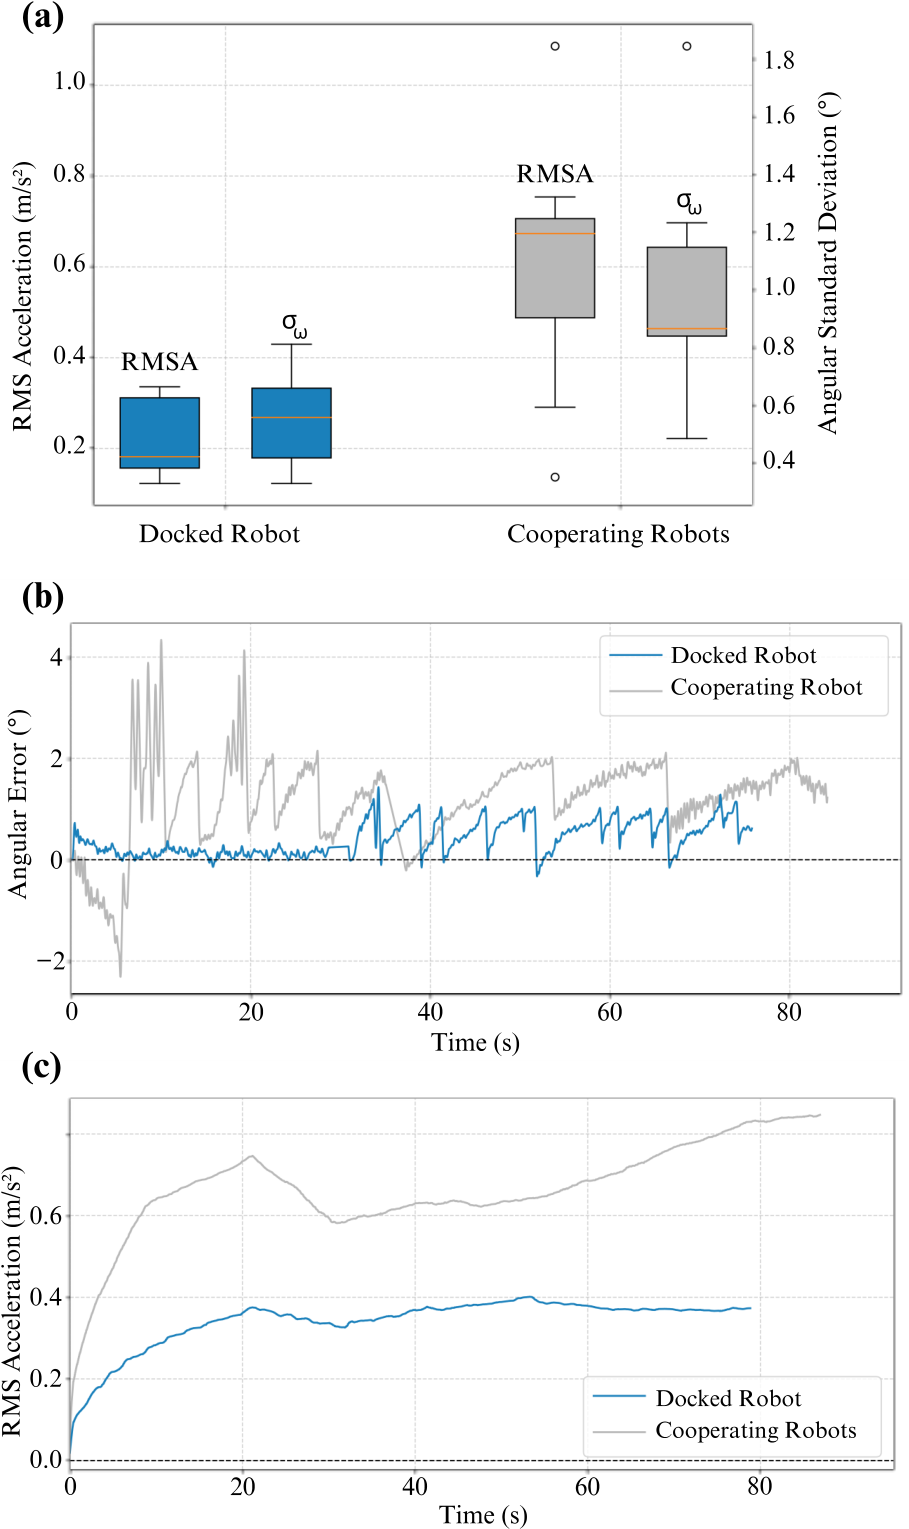
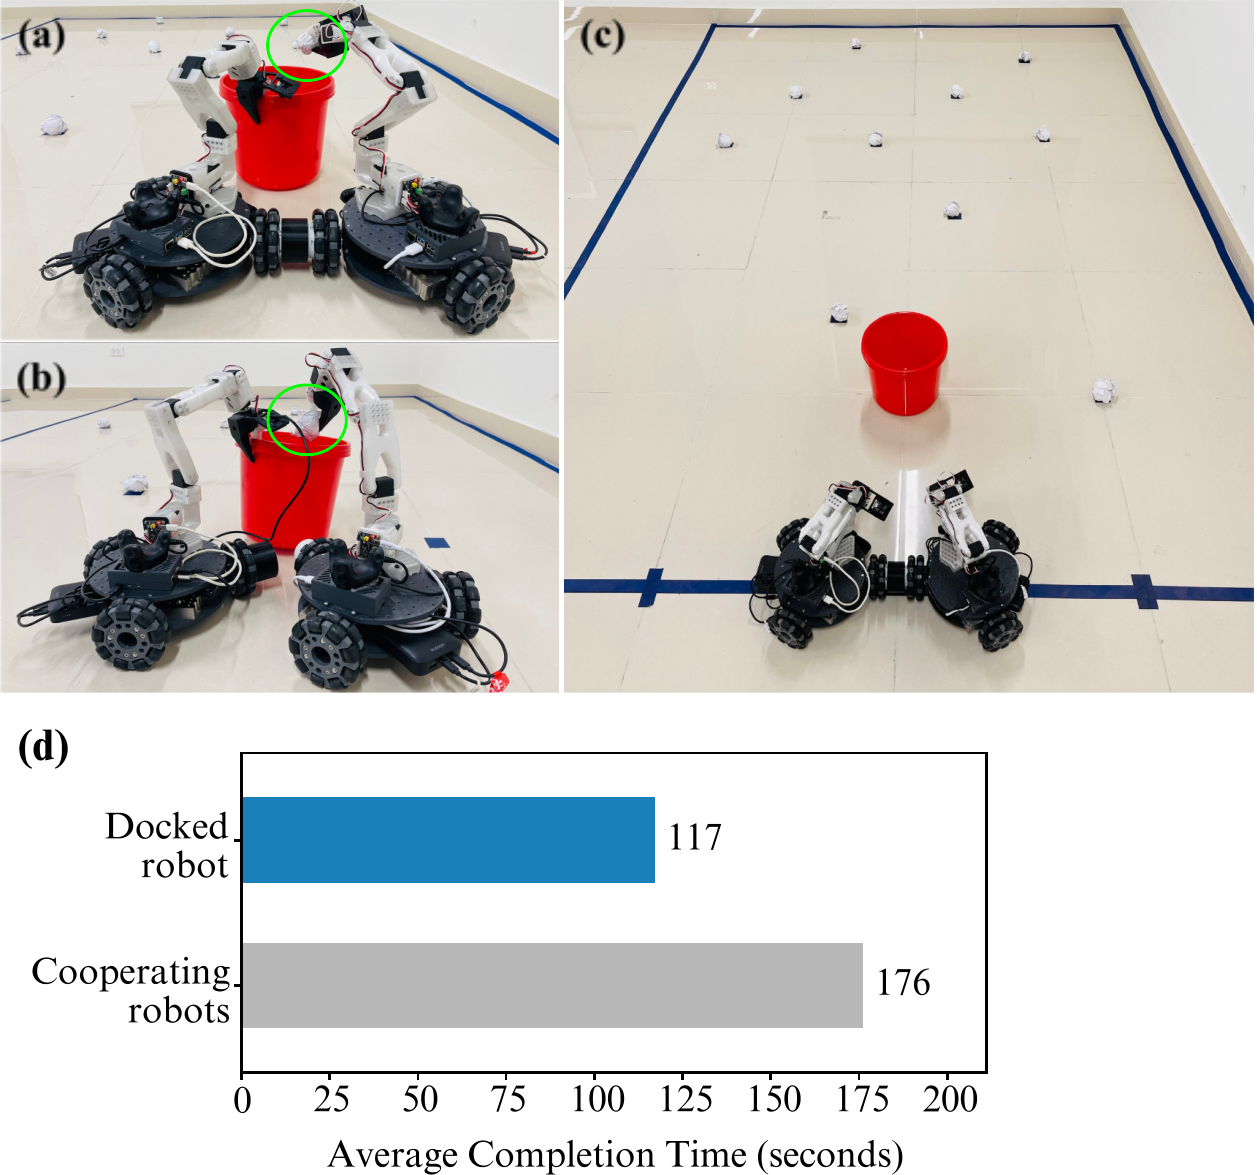
Four experiments evaluate autonomous docking, post-reconfiguration motion, dynamic stability, and collaborative task performance.
15 trials across four lighting conditions
0.2226 vs. 0.6068 m/s²
0.56° vs. 1.10° deviation
Compared with 84 s cooperating
If you find this work useful, please cite the paper.
@inproceedings{nguyen2026mobidock,
  title     = {MobiDock: Design and Control of a Modular
               Self-Reconfigurable Bimanual Mobile Manipulator
               via Robotic Docking},
  author    = {Nguyen, Xuan Thuan and Nguyen, Khac Nam and
               Tran, Ngoc Duy and Mac, Thi Thoa and Nguyen, Anh and
               Ly, Hoang Hiep and Ta, Tung D.},
  booktitle = {IEEE/RSJ International Conference on
               Intelligent Robots and Systems (IROS)},
  year      = {2026}
}