Passive pneumatic hybrid gripper
Rigid finger links and soft-ring joints support both probing and grasping with a simple pneumatic system.
IROS 2026 project page
1The University of Tokyo, Japan
2Mohamed bin Zayed University of Artificial Intelligence, UAE
3University of Liverpool, UK
4Hanoi University of Science and Technology, Vietnam
5Keio University, Japan
A passive soft-rigid hybrid gripper uses pressure changes inside pneumatic soft-ring joints to probe local object stiffness, then selects stable grasp locations without embedded tactile arrays.
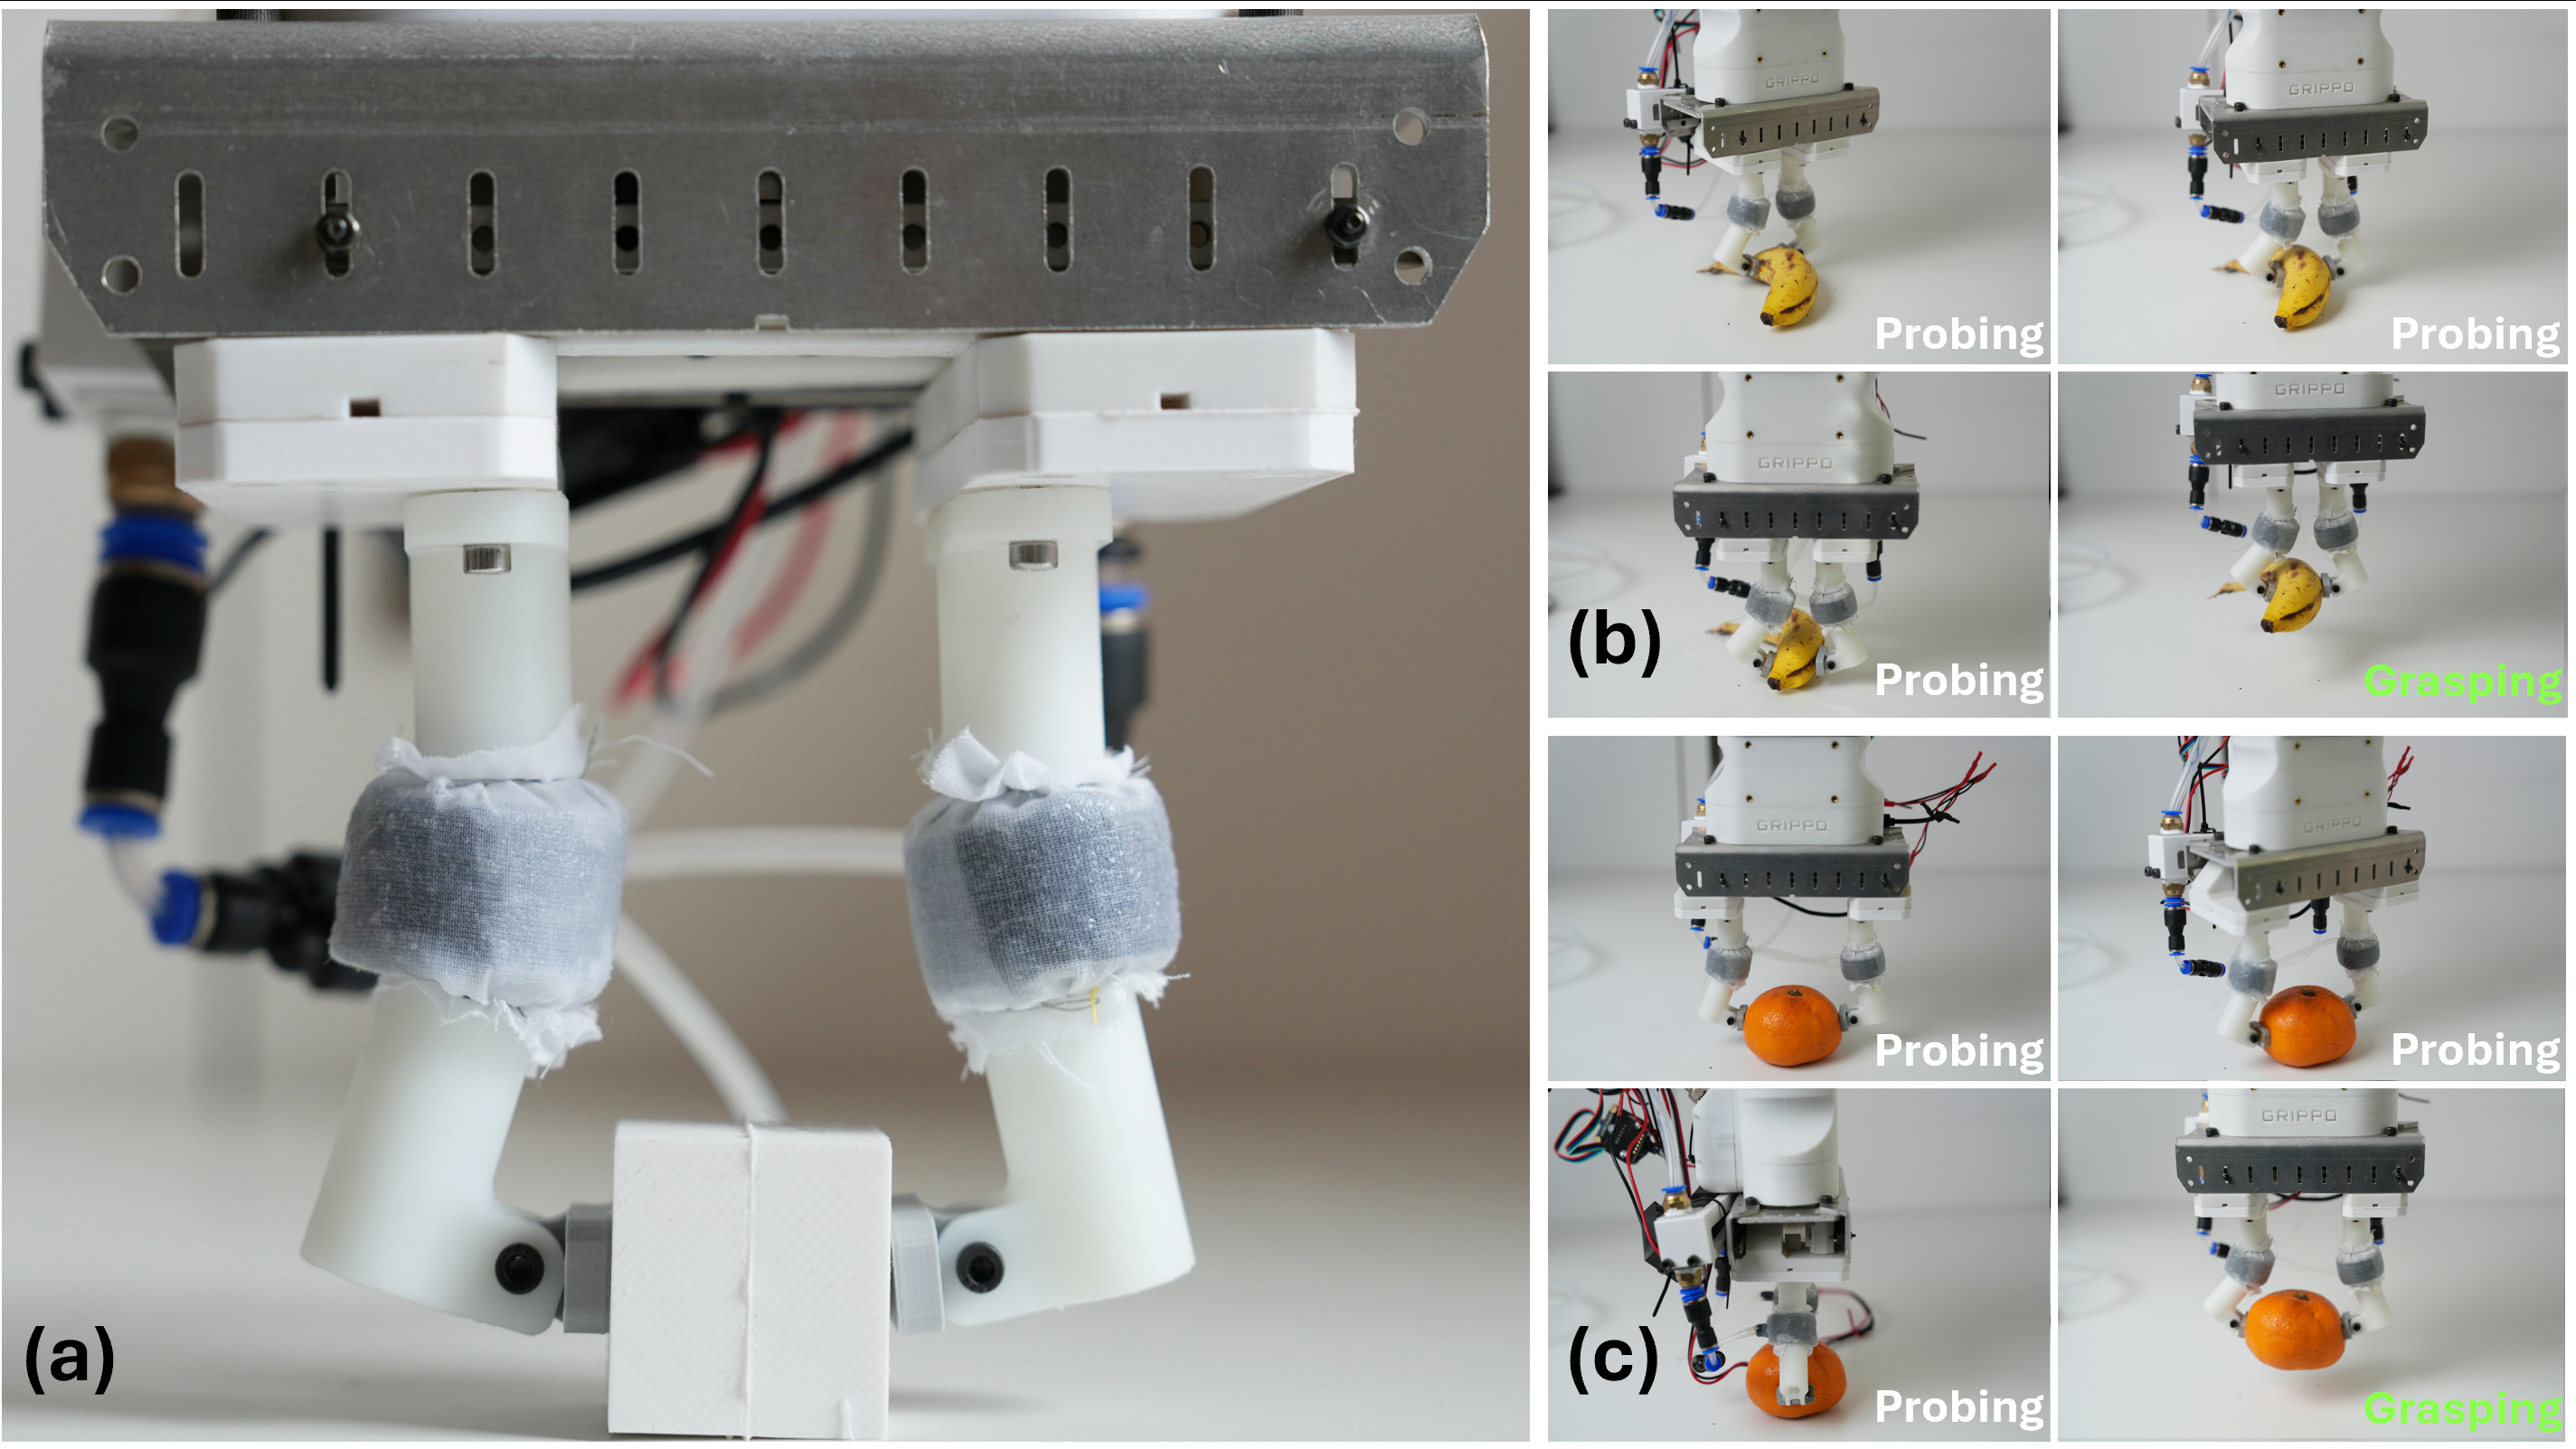
Overview
Grasping deformable objects with varying stiffness remains a significant challenge in robotics. Estimating the local stiffness of a target object is important for determining an optimal grasp pose that enables stable pickup without damaging the object. This paper presents a probe-to-grasp manipulation framework for estimating the relative stiffness of objects using a passive soft-rigid two-finger hybrid gripper equipped with self-sensing pneumatic variable-stiffness joints.
Each finger consists of two rigid links connected by a soft pneumatic ring placed at the joint, enabling compliant interaction and controllable joint stiffness via internal pressurization. By measuring pressure inside the pneumatic ring, the system estimates interaction force during contact. The probing strategy then infers relative object stiffness by correlating estimated normal force with known gripper closing displacement.
Rigid finger links and soft-ring joints support both probing and grasping with a simple pneumatic system.
Pressure variation in the soft ring is used as a low-cost signal for contact force and relative stiffness estimation.
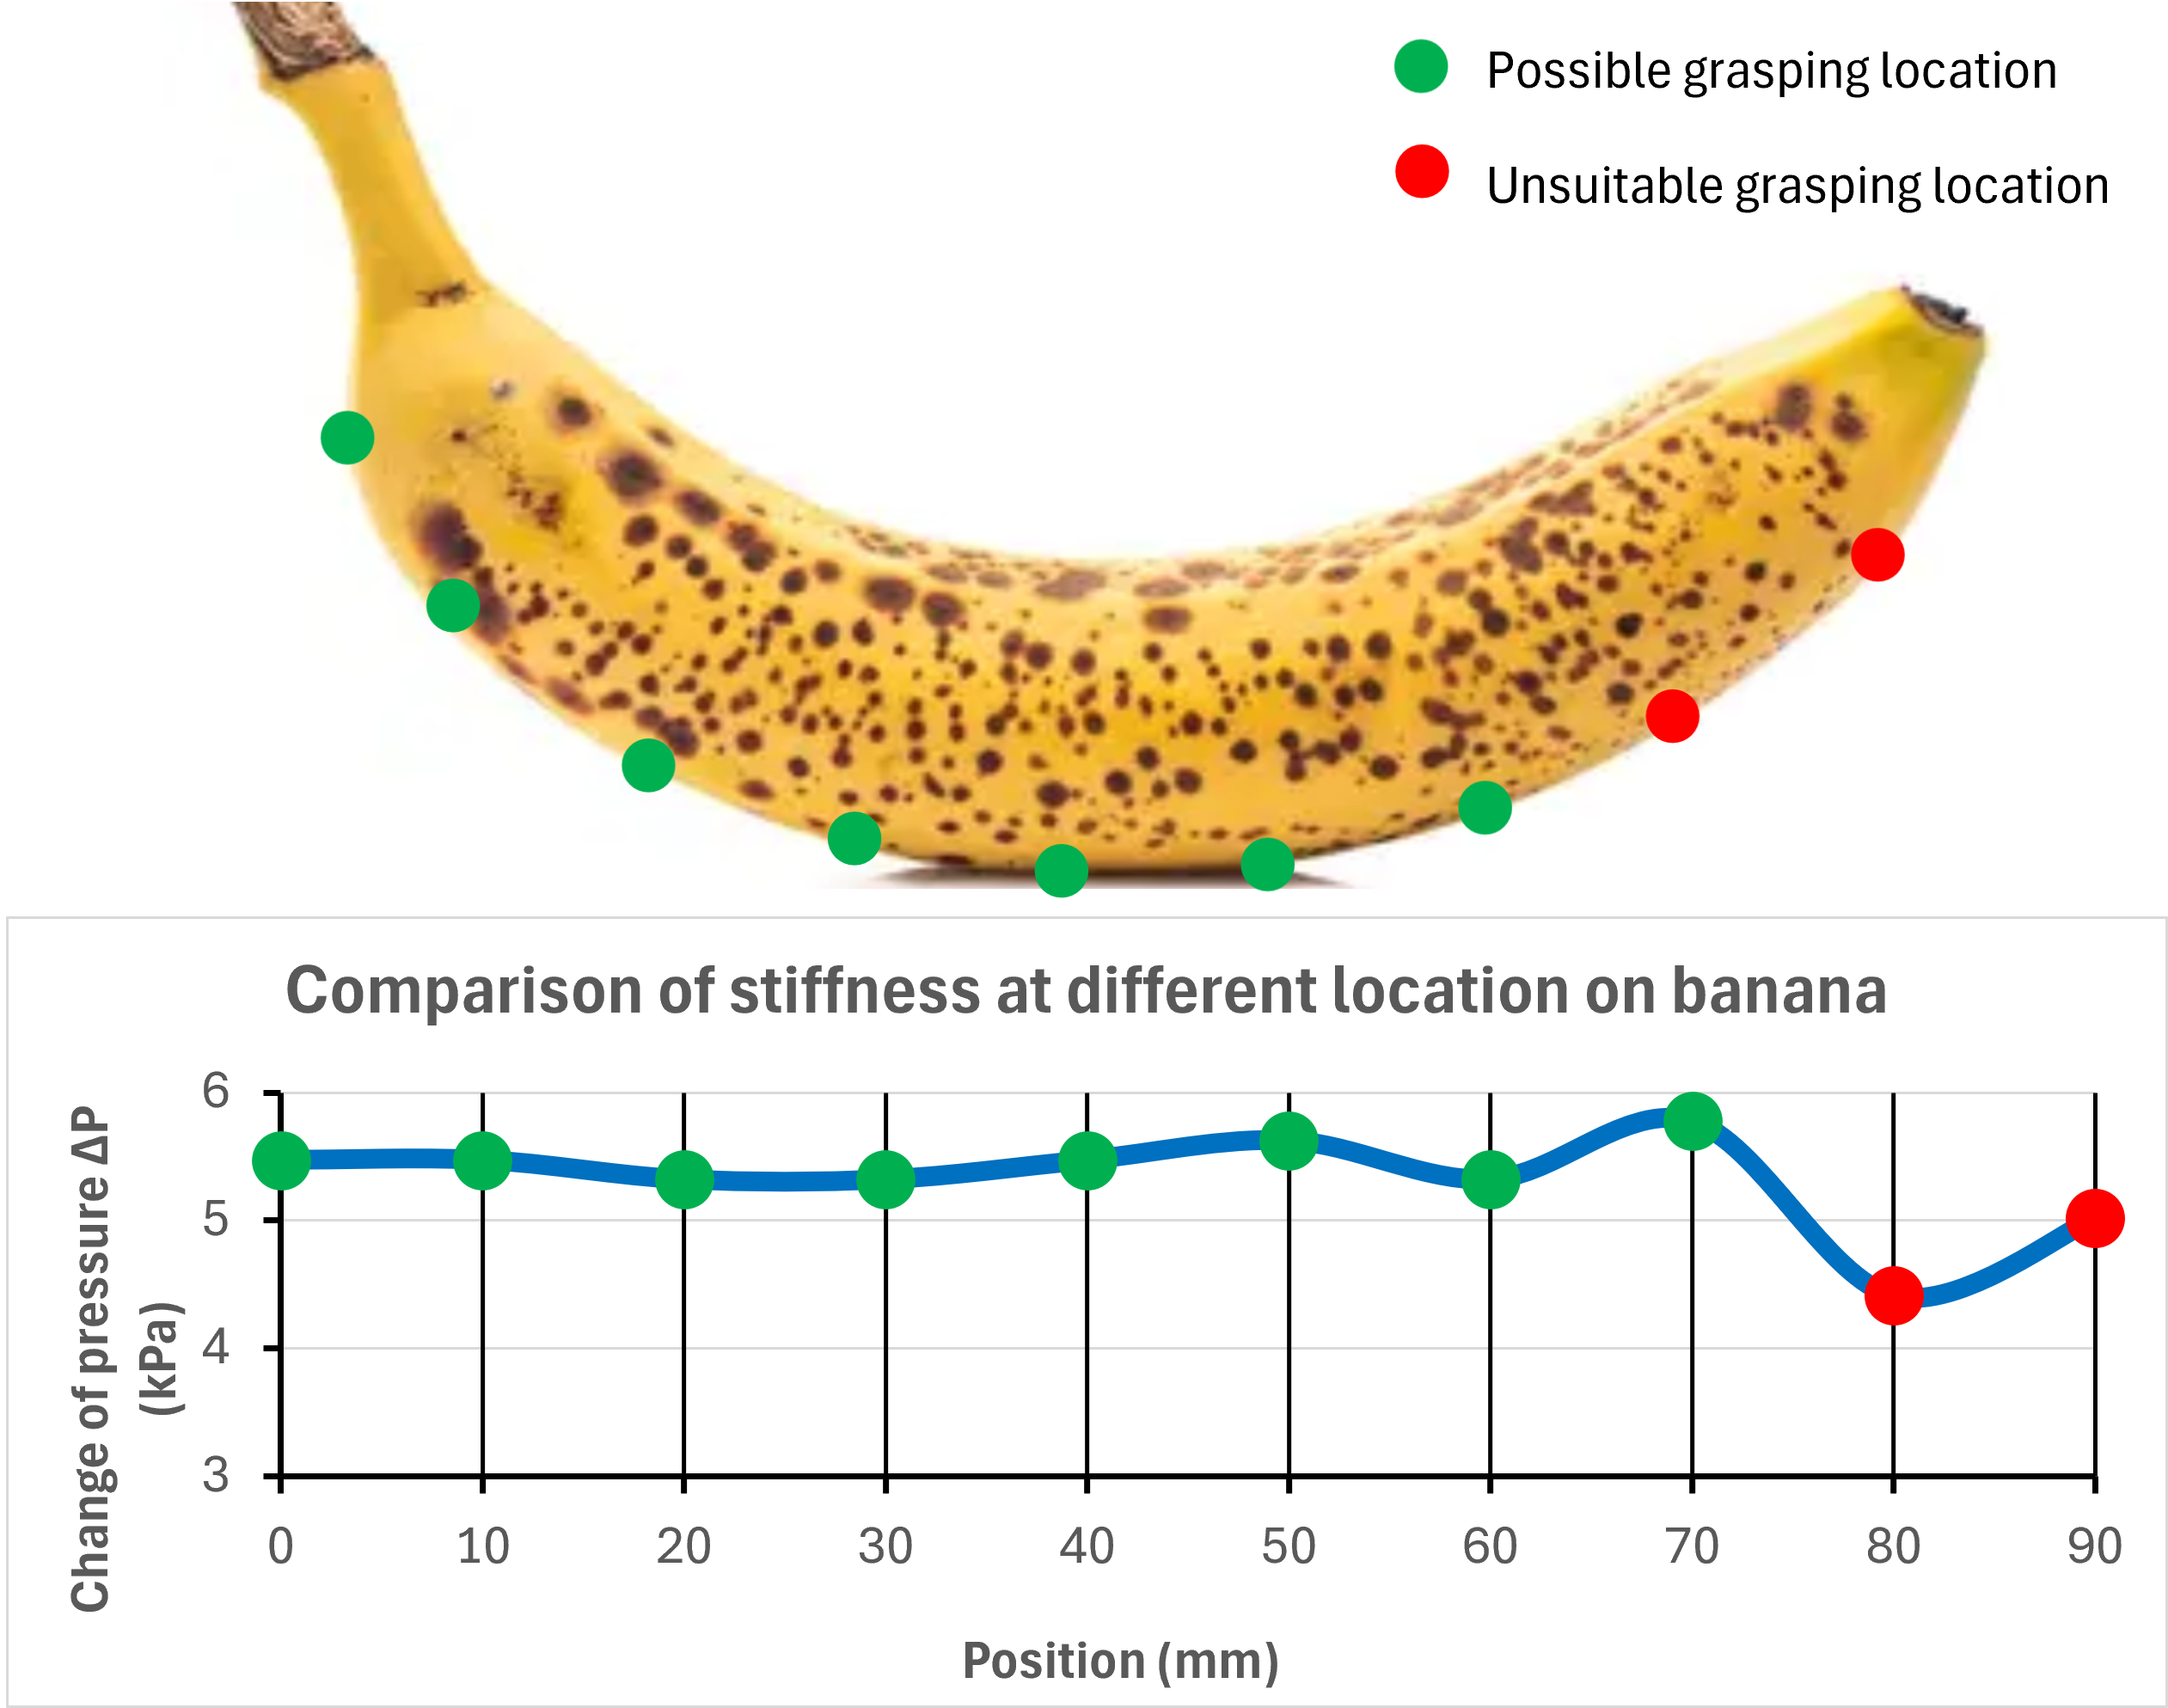
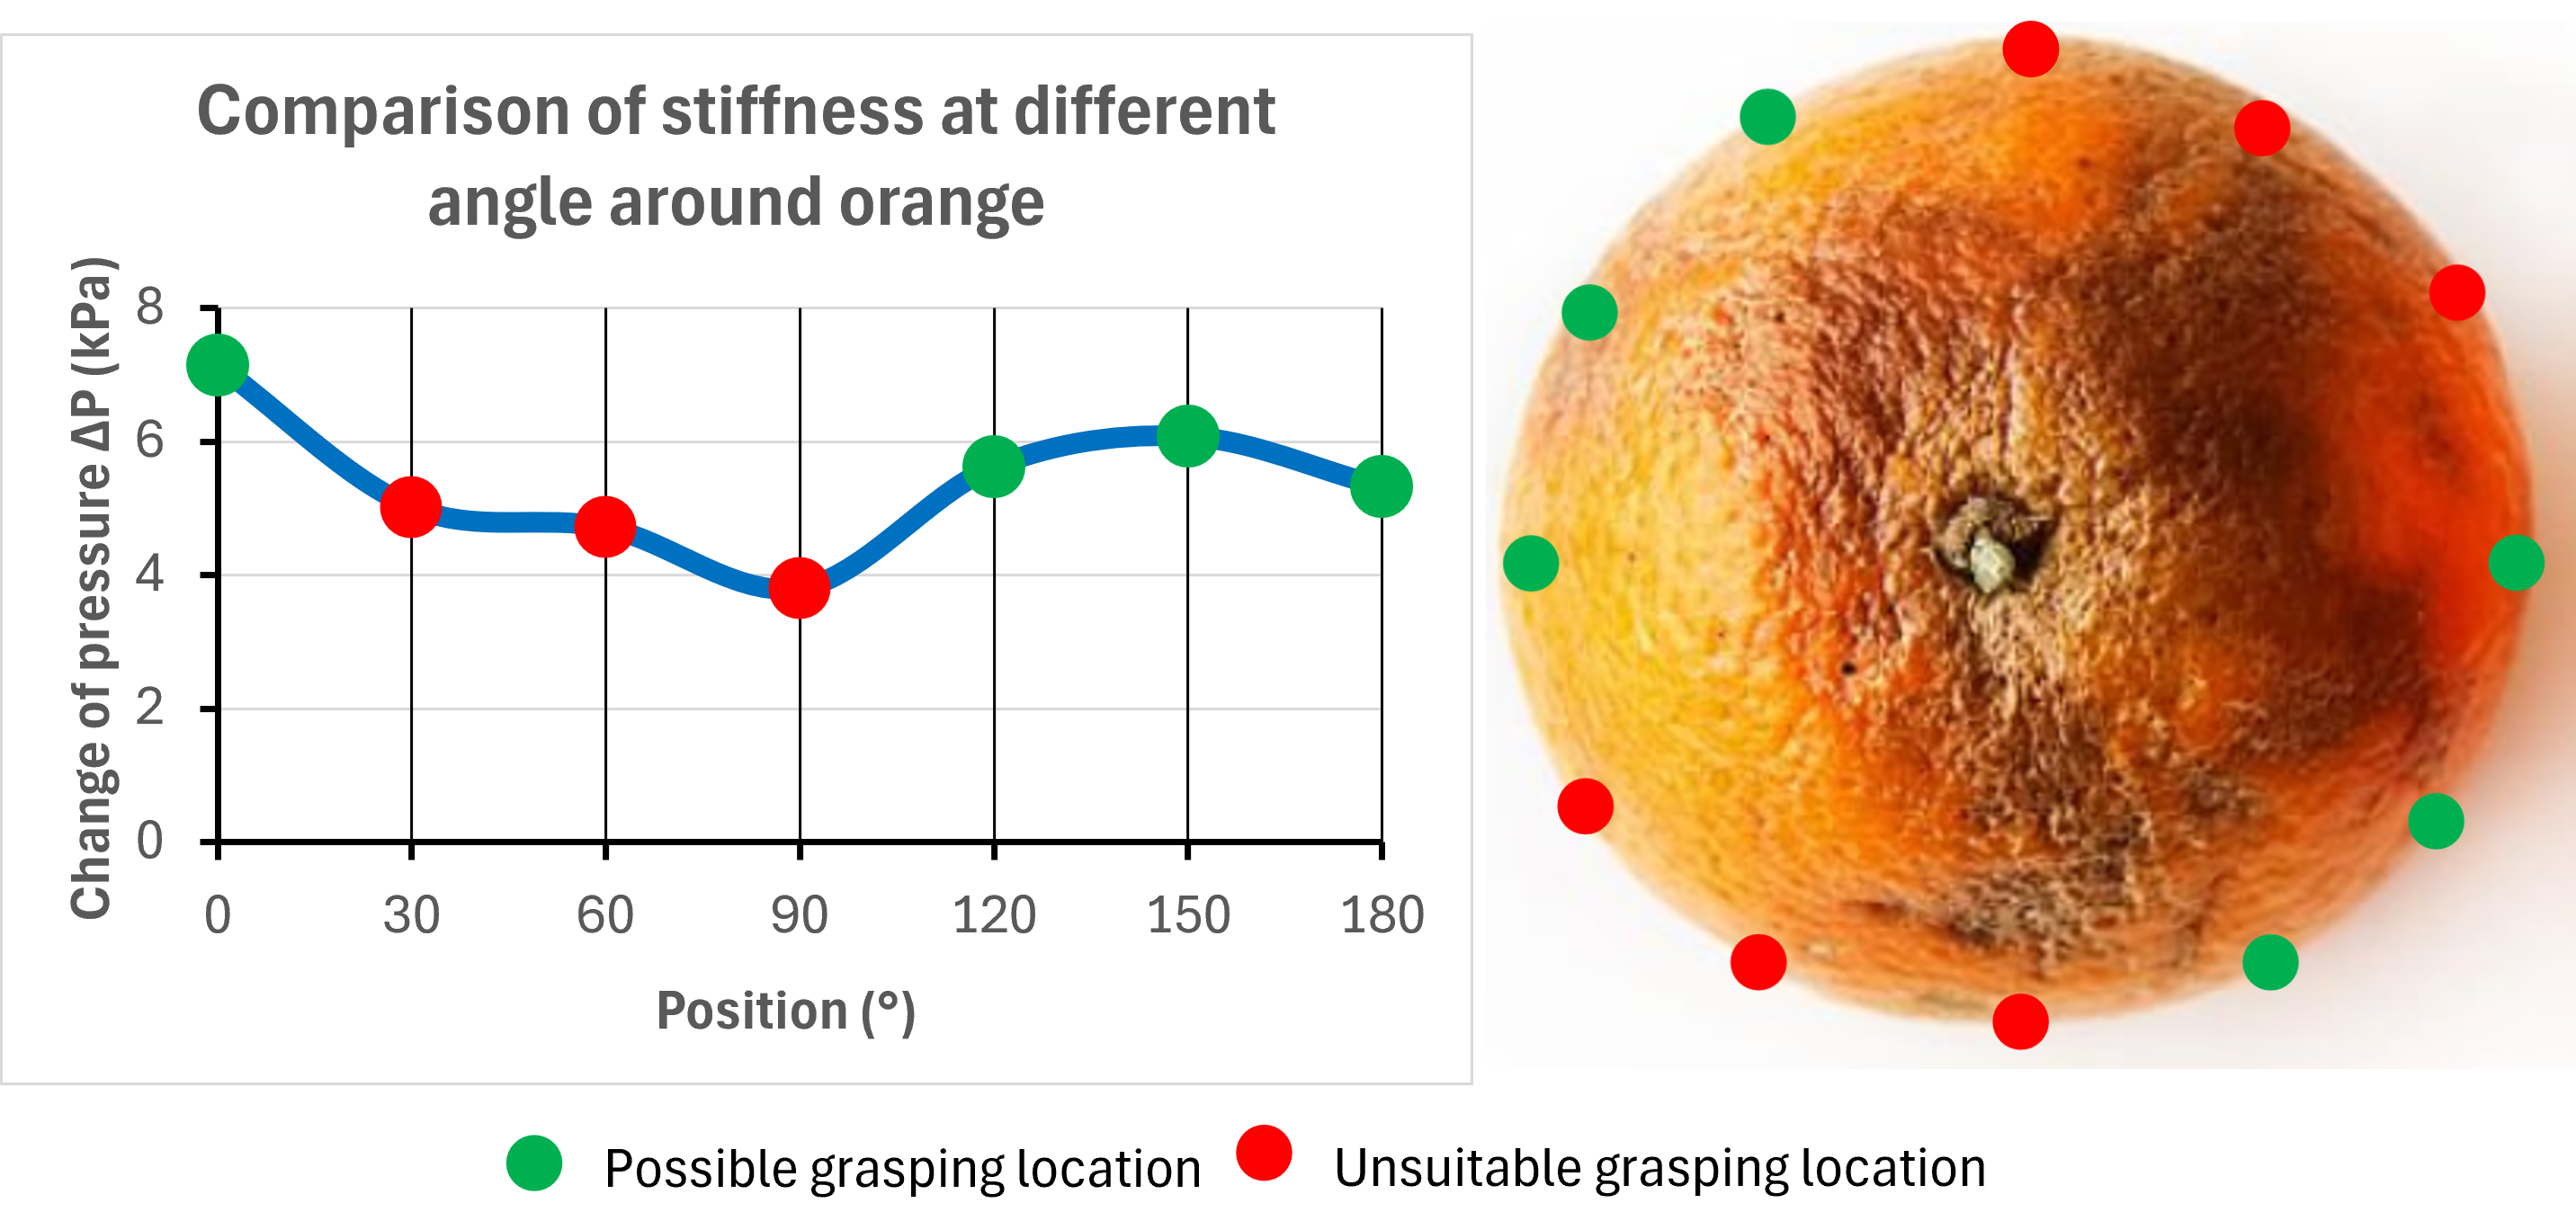
Fruit experiments show how the gripper probes candidate regions and avoids softer locations during grasp planning.
Demonstration
Hardware
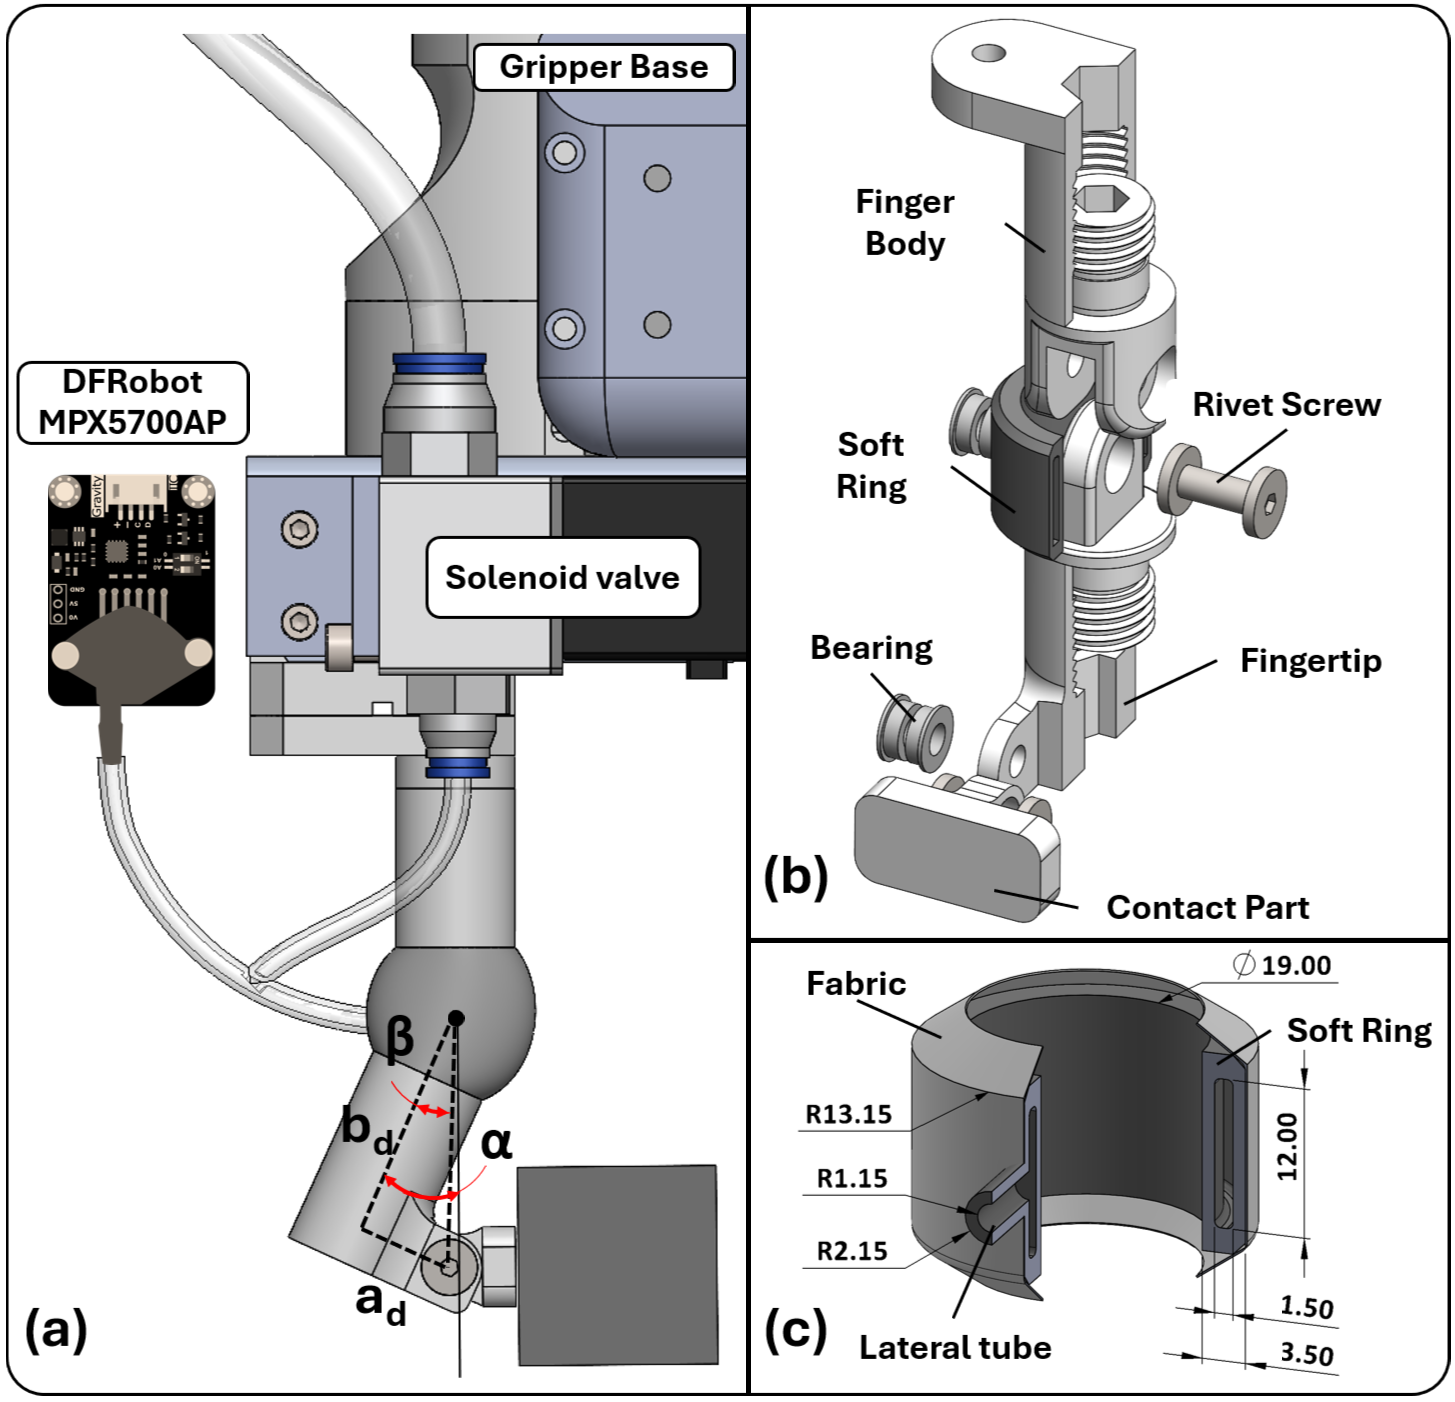
Each gripper finger uses two rigid links joined by a passive pneumatic soft ring. Internal pressure adjusts joint stiffness while preserving compliance during contact with fragile and deformable objects.
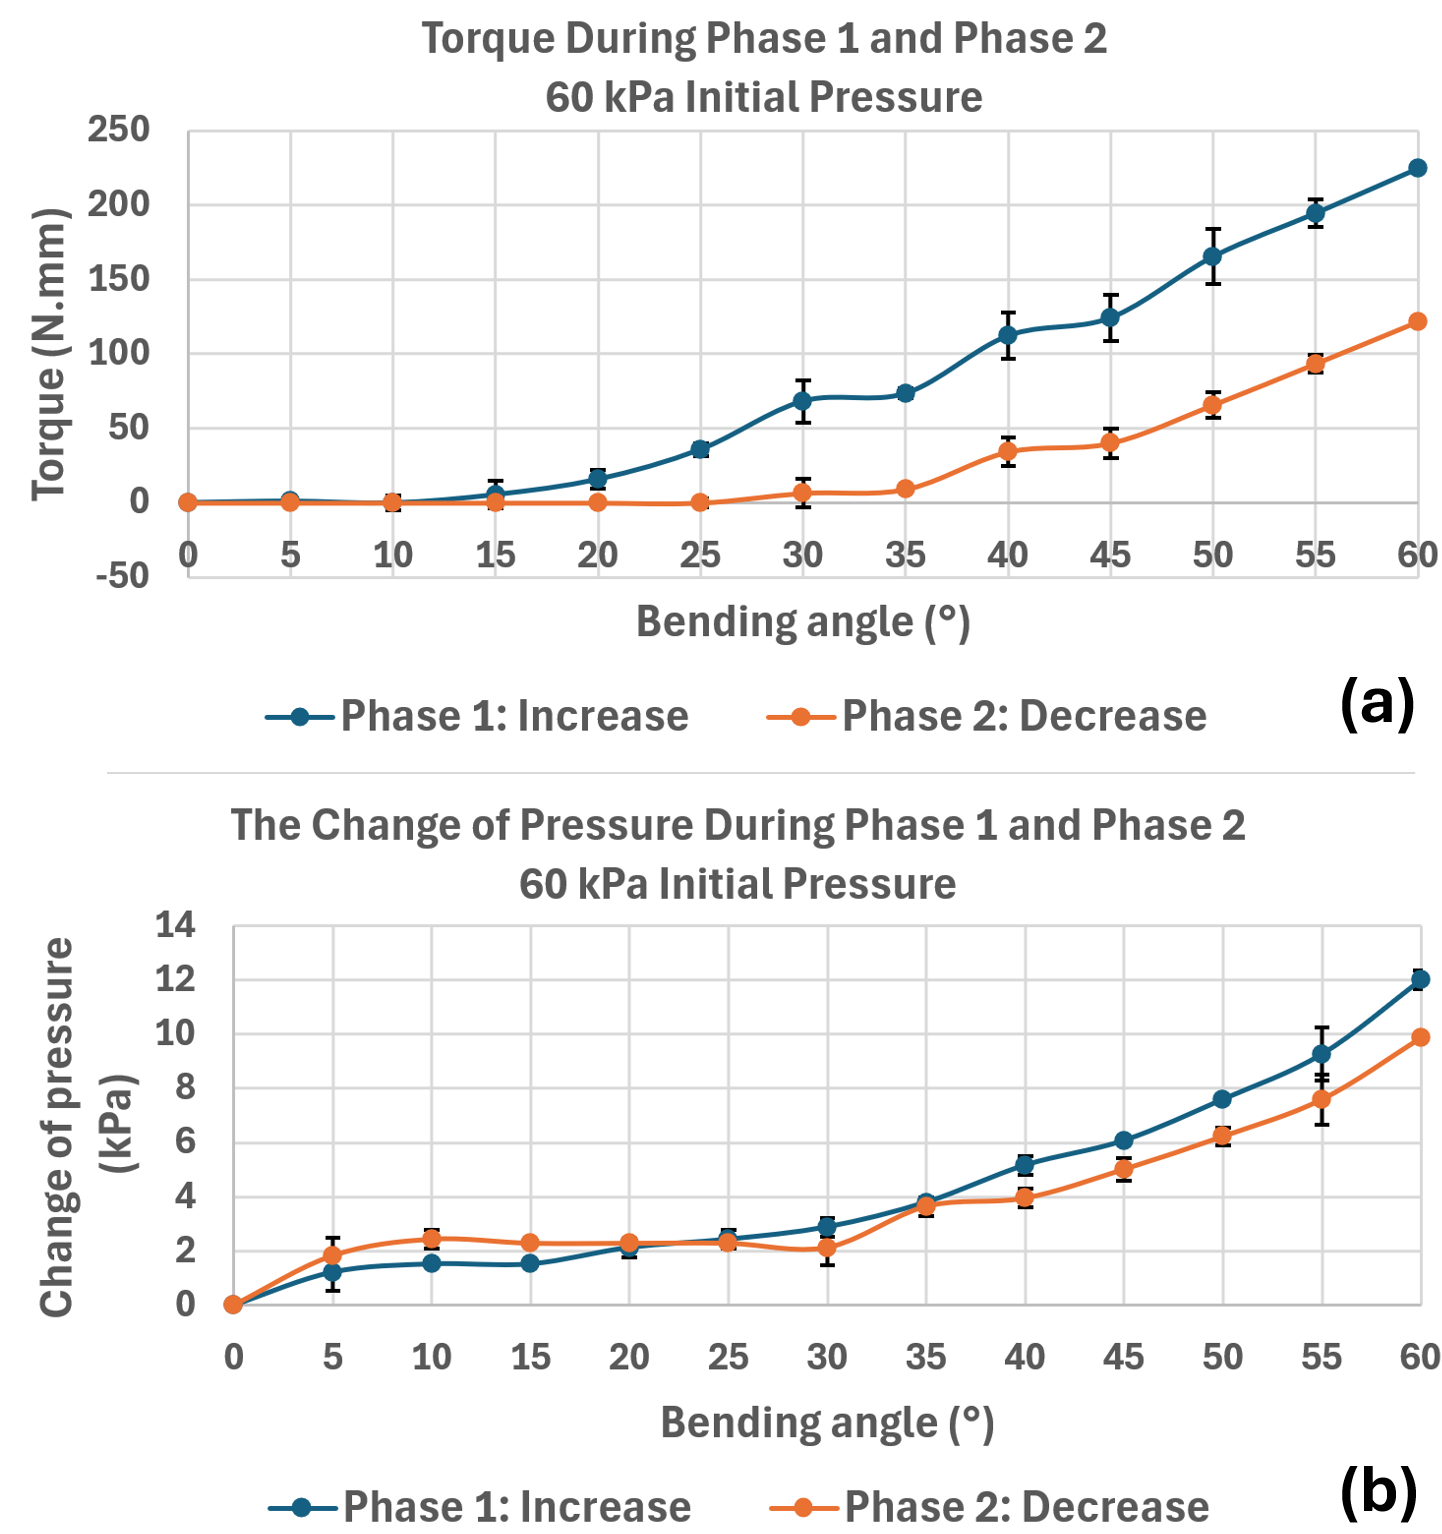
A pressure sensor monitors the pneumatic ring directly. When the finger contacts an object, bending and constrained air volume create a measurable pressure change that is mapped to interaction force through experimental characterization.
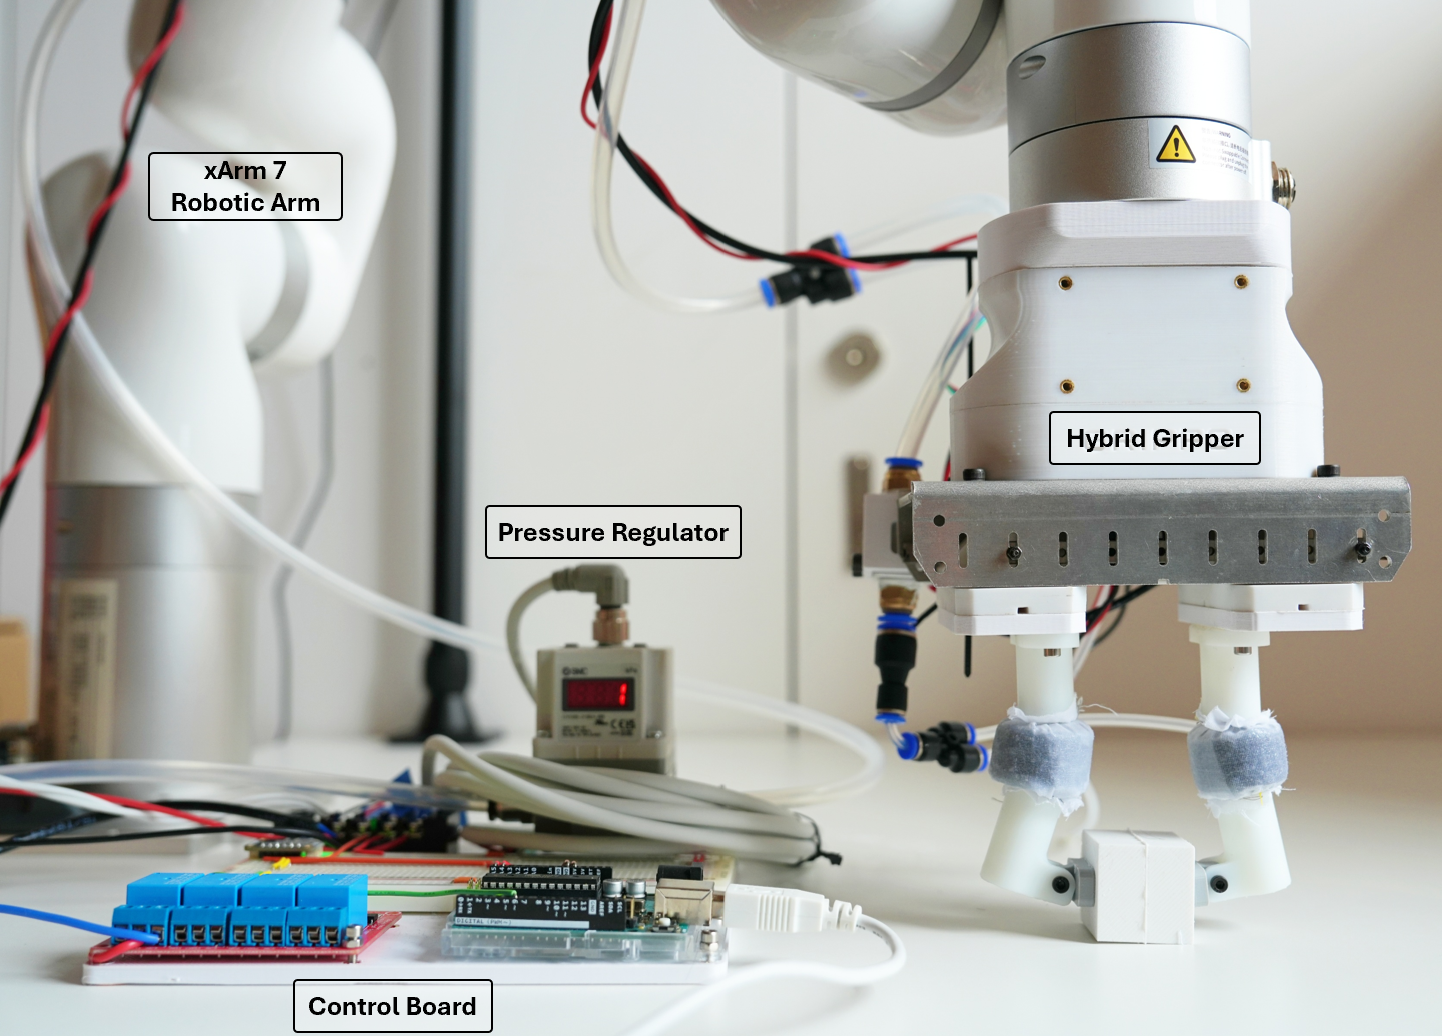
Probe-to-grasp
The soft-ring joint is pressurized, then air volume is constrained by the pneumatic system.
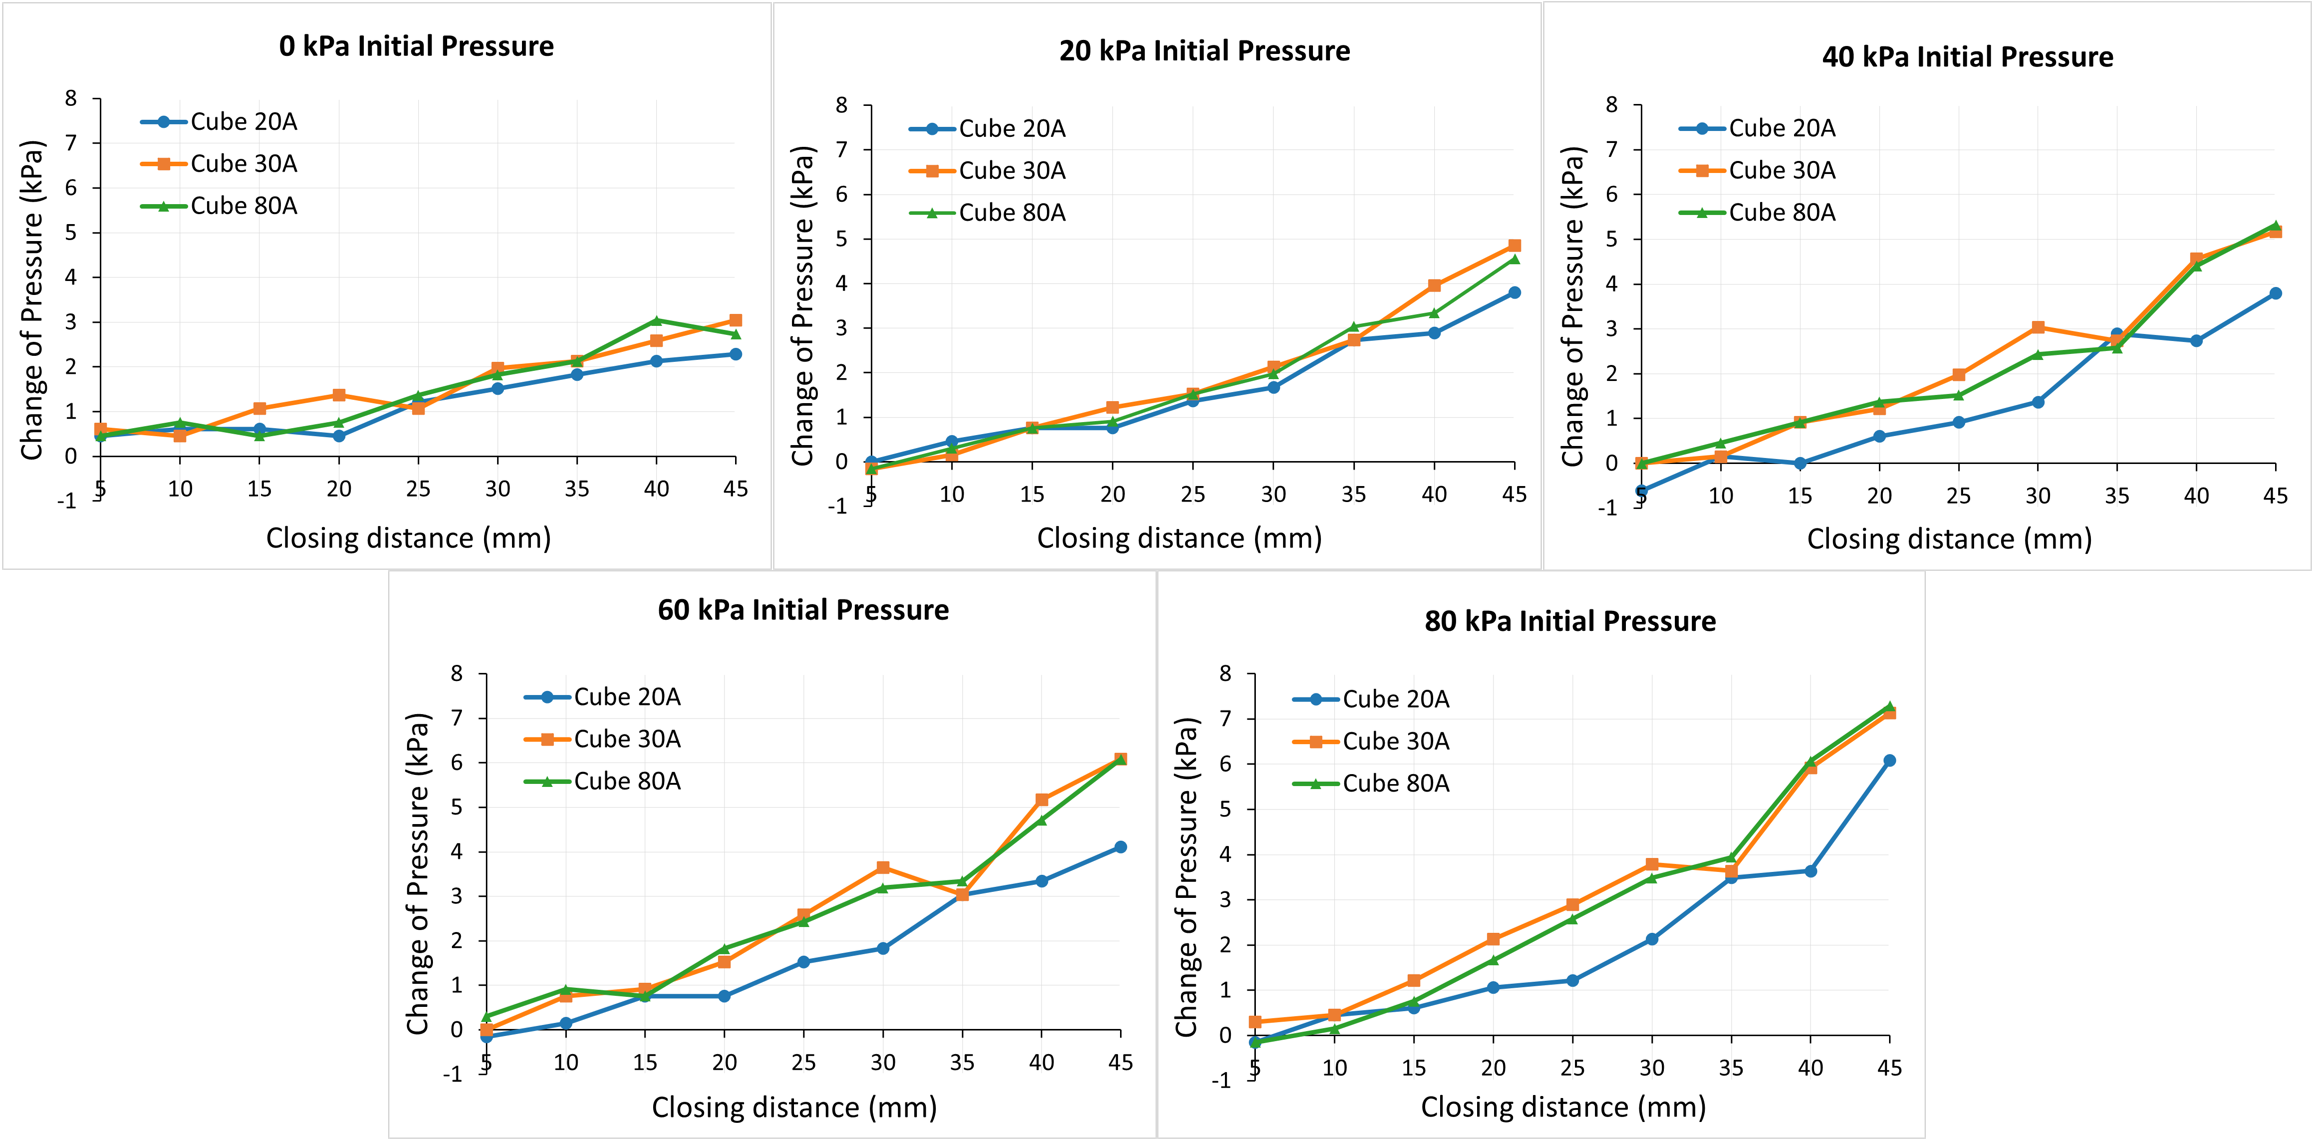
The robot closes the gripper by known displacements while pressure variation is recorded.
For the same closing motion, stiffer contact regions produce larger pressure changes.
The gripper chooses firmer regions for stable grasping and avoids soft areas that may be damaged.
Object stiffness is treated as force over deformation; pressure change provides the practical force cue.
Measured pressure variation increases with relative object stiffness under matched probing conditions.
Experiments
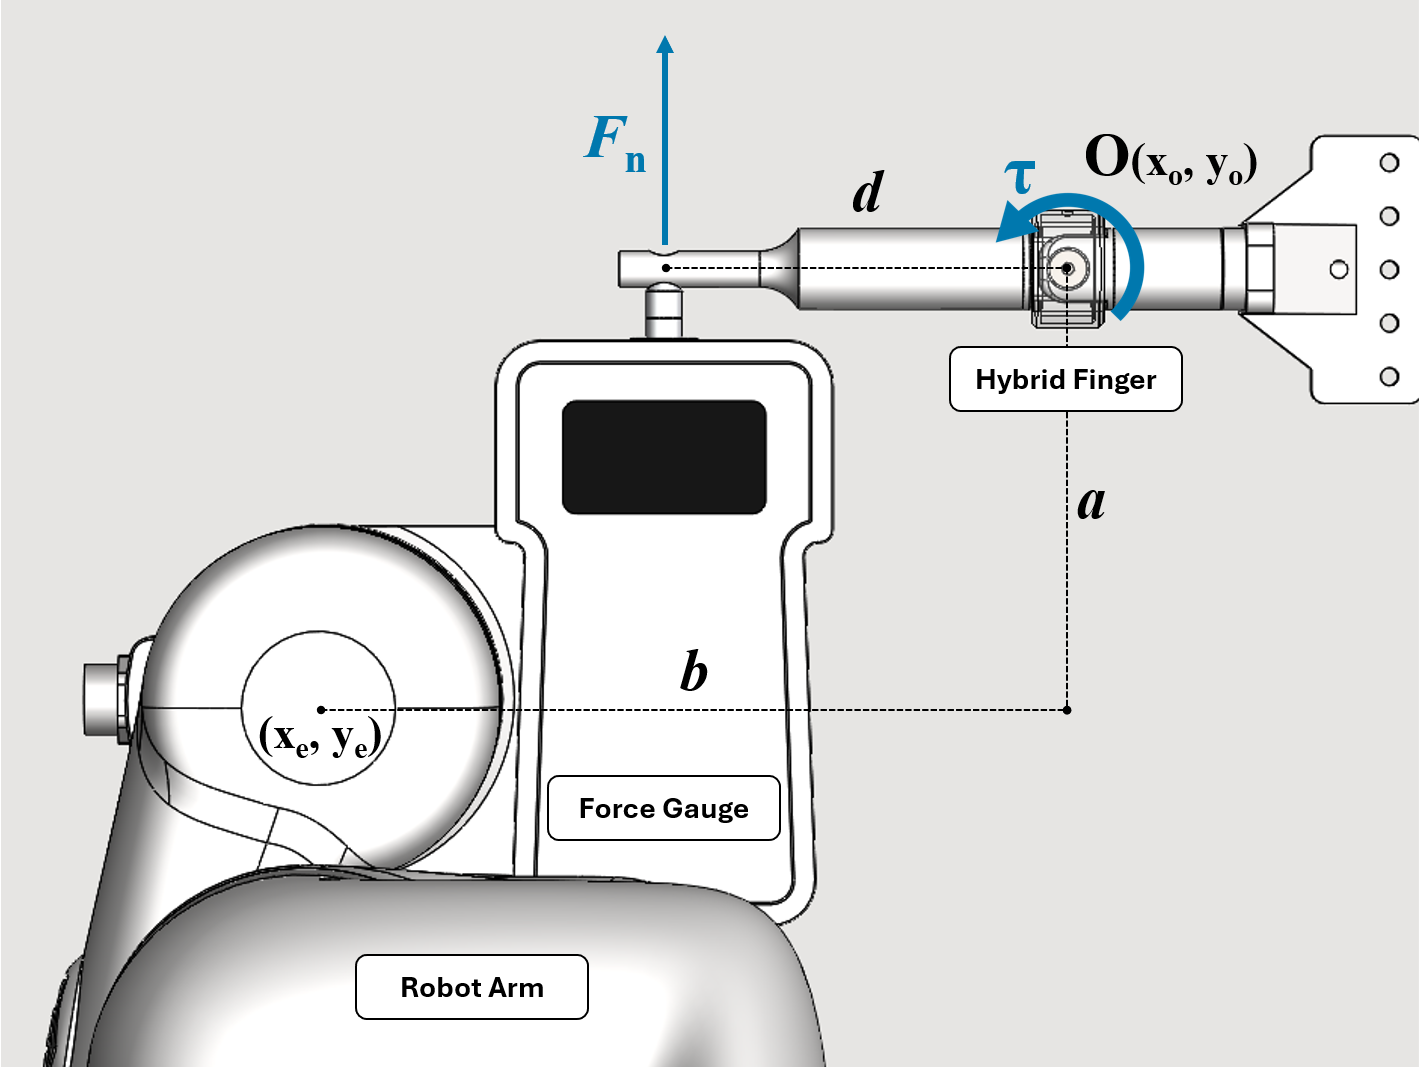

Real-world validation
The current system is limited by pressure sensor resolution, hysteresis in the soft material, air leakage at pneumatic fittings, and sensing on only one fingertip. Future work will use simulation and improved sensing hardware to refine the soft-ring design and improve repeatability across broader object classes.
Citation
@misc{tran2026probetograsp,
  title={Probe-to-Grasp Manipulation Using Self-Sensing Pneumatic Variable-Stiffness Joints},
  author={Tran, Ngoc-Duy and Fan, Yeman and Dai, Feng and Nguyen, Khang and Nguyen, Anh and Ly, Hoang-Hiep and Ta, Tung D. and Chiba, Shigeru},
  year={2026}
}